Yanjiu Conference logo

Call for Papers – ICHRAL 2027, Hong Kong

International Conference on Humanoid Robotics and Adaptive Locomotion — ICHRAL 2027

Dates

25–26 January 2027

Venue

Hong Kong, Hong Kong

Field

Humanoid Robotics and Adaptive Locomotion

Topics of ICHRAL 2027

Original papers are invited in Humanoid Robotics and Adaptive Locomotion. Submit by 24 December 2026.

Submit Your Paper

Topics include, but are not limited to:

Robot Design and Dynamics

  • Innovative designs for humanoid robotics
  • Dynamics of bipedal locomotion
  • Impact of weight distribution on movement
Control Systems and Algorithms

  • Adaptive control strategies for locomotion
  • Machine learning for behavior adaptation
  • Real-time processing in complex environments

Sensory Perception and Feedback

  • Integration of sensory data for navigation
  • Haptic feedback in humanoid robots
  • Perception mechanisms in dynamic settings

Interdisciplinary Approaches

  • Collaboration between robotics and biomechanics
  • Cognitive models in robotics design
  • Ethical considerations in humanoid applications

Application in Real-World Environments

  • Humanoid robots in search and rescue
  • Robots for elderly assistance and care
  • Performance in unstructured environments

Important Dates

Conference opens in

00days
00hours
00min
00sec
  1. Step 1

    Submission Deadline

  2. Step 2

    Registration Deadline

  3. Step 3

    Conference Date

Download

Get the official templates and forms for ICHRAL 2027. Use the latest versions when preparing your submission.

Peer Review Process

Follow each step from abstract submission to awards and recognition.
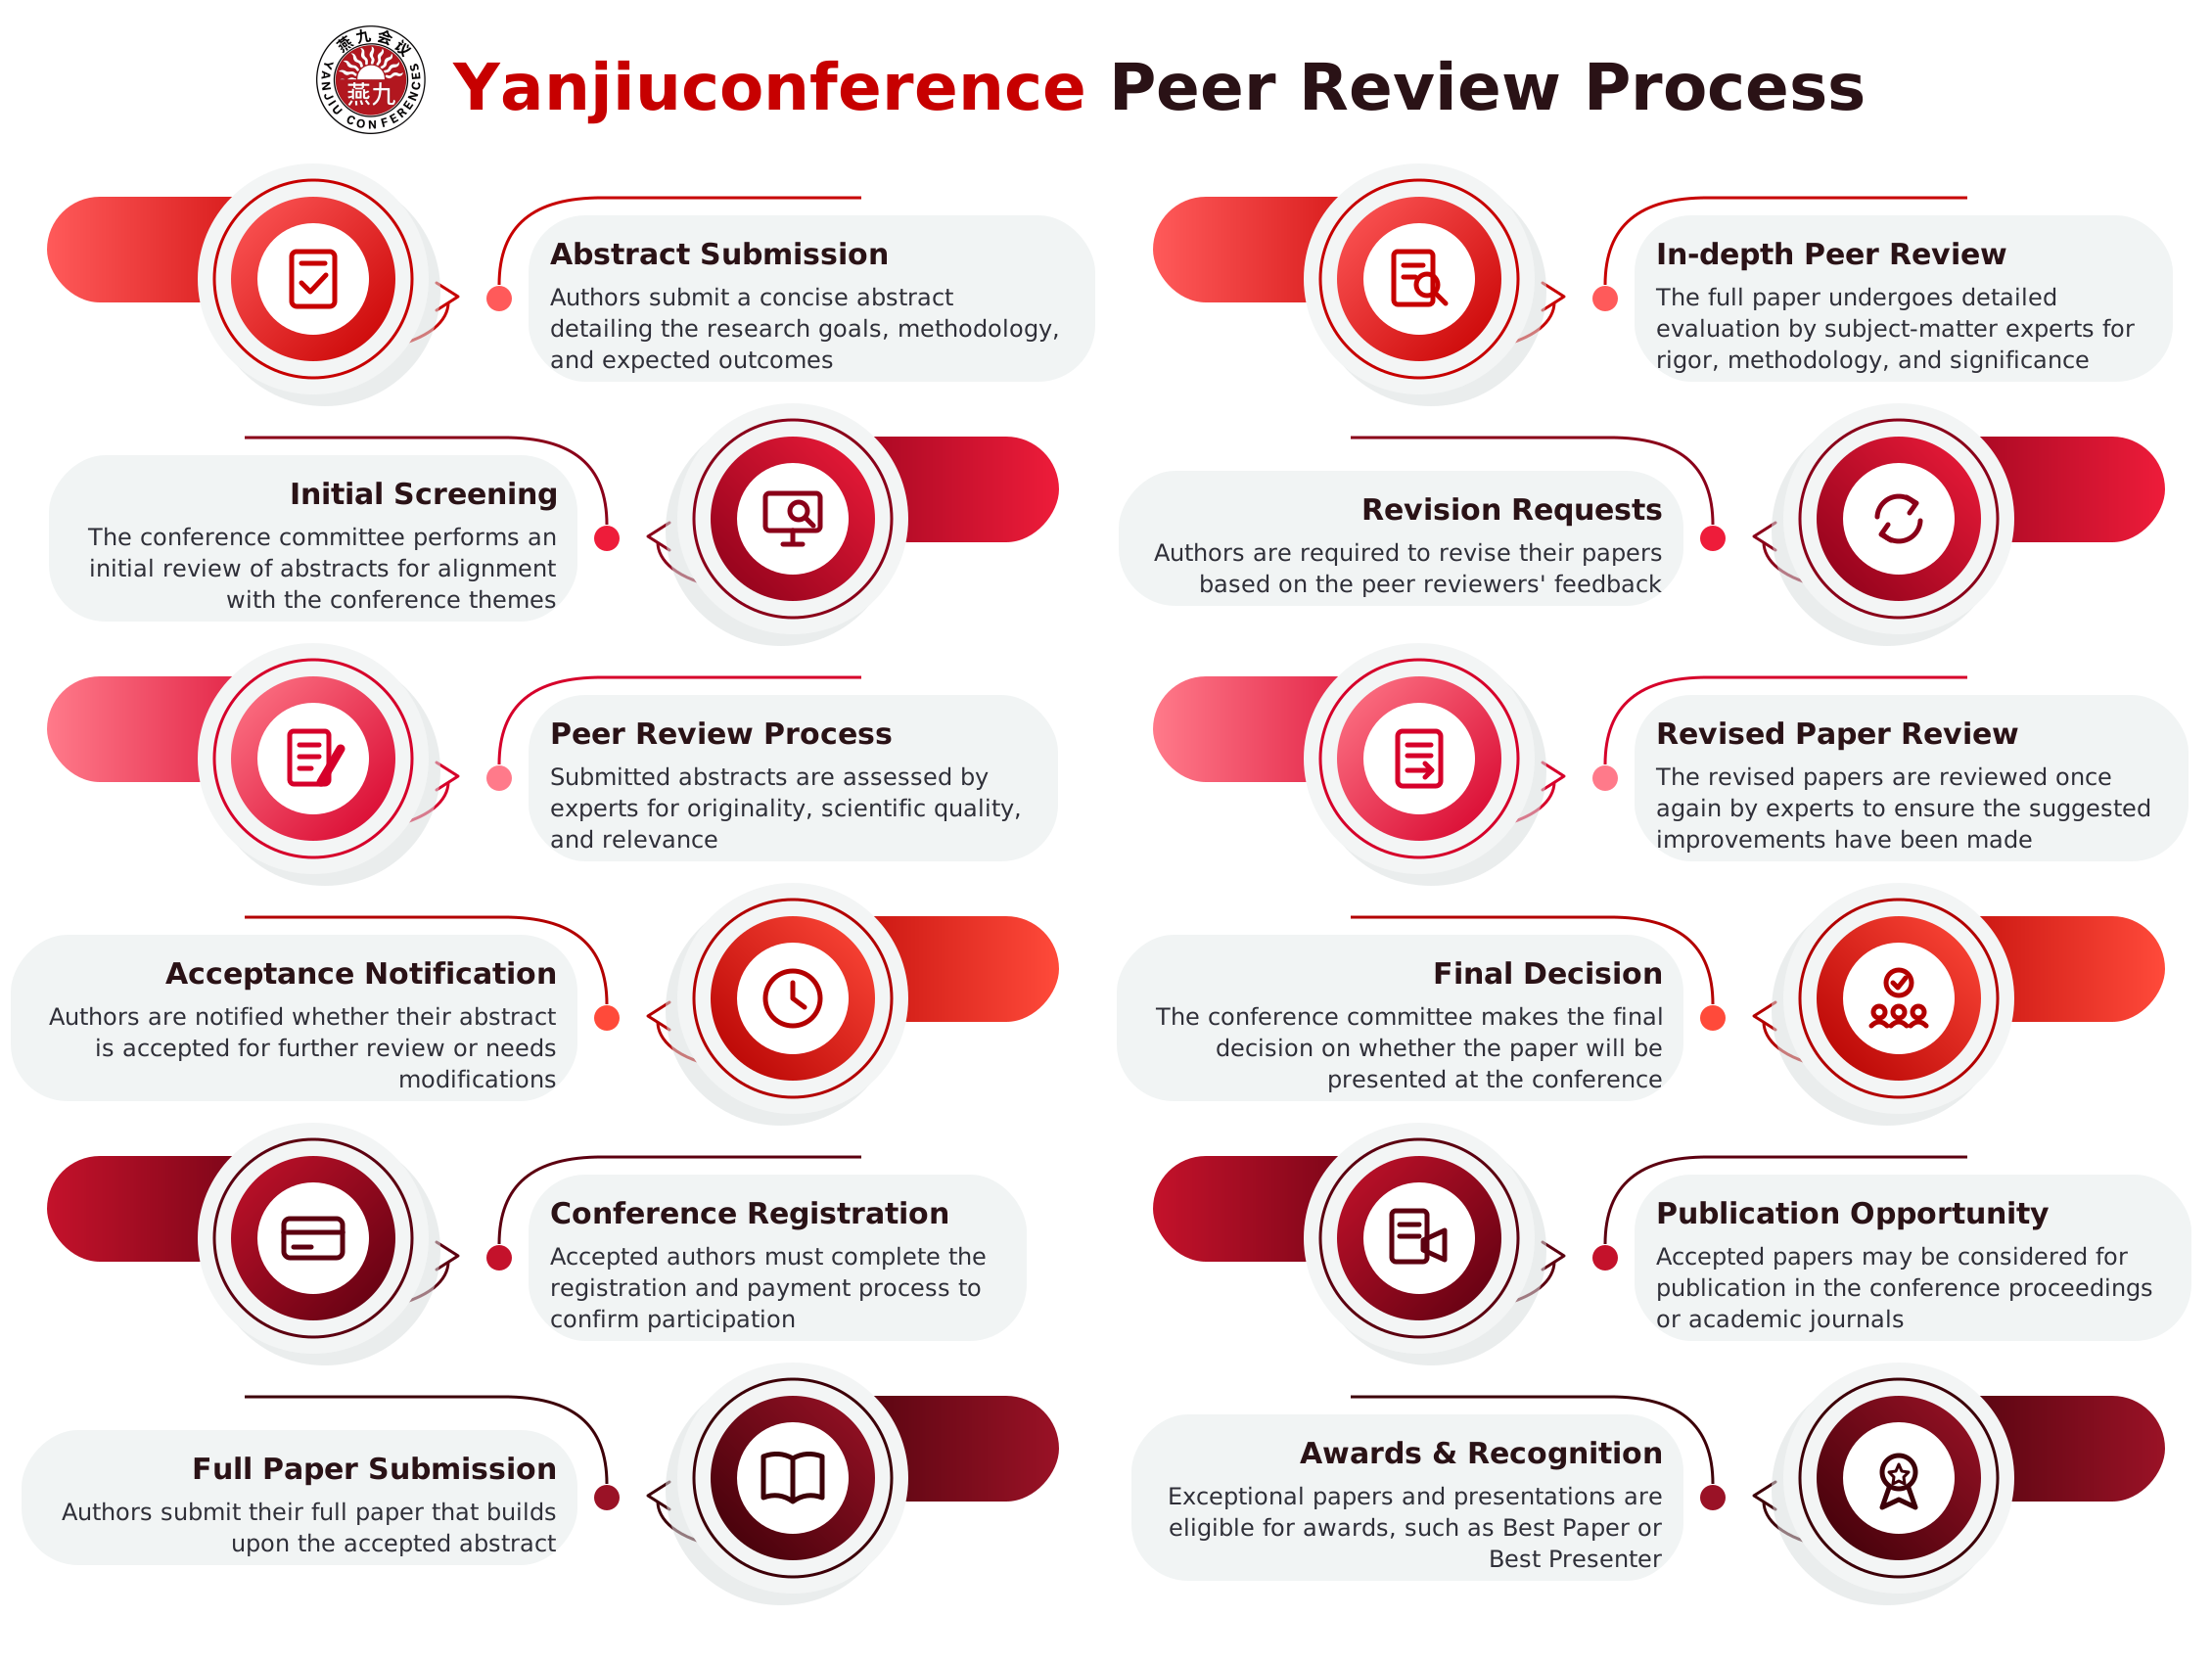
Yanjiuconference peer review process: 12 steps from abstract submission to awards and recognition

See You in Hong Kong This January

Present your research, meet peers from over 50 countries and help shape the future of Humanoid Robotics and Adaptive Locomotion.