Yanjiu Conference logo

Call for Papers – ICIMRN 2027, Tagaytay

International Conference on Intelligent Mobile Robotics and Navigation — ICIMRN 2027

Dates

17–18 April 2027

Venue

Tagaytay, Philippines

Field

Intelligent Mobile Robotics and Navigation

Topics of ICIMRN 2027

Original papers are invited in Intelligent Mobile Robotics and Navigation. Submit by 16 March 2027.

Submit Your Paper

Topics include, but are not limited to:

Autonomous Navigation Strategies

  • Development of real-time mapping techniques
  • Sensor fusion for obstacle detection
  • Machine learning for path planning

Human-Robot Interaction

  • Designing intuitive control interfaces
  • Social acceptance of robots in public spaces
  • Collaborative tasks in shared environments

Sustainable Robotics

  • Energy-efficient algorithms for mobile robots
  • Eco-friendly materials in robot design
  • Impact assessments of robotic technologies

Artificial Intelligence in Robotics

  • Applications of reinforcement learning in navigation
  • AI-driven decision-making processes
  • Ethical considerations of AI in robotics

Interdisciplinary Approaches

  • Collaboration between engineering and cognitive science
  • Integration of robotics with health care solutions
  • Robotics in environmental monitoring

Challenges in Robotic Mobility

  • Navigating complex urban terrains
  • Robustness against dynamic obstacles
  • Handling extreme environmental conditions

Important Dates

Conference opens in

00days
00hours
00min
00sec
  1. Step 1

    Submission Deadline

  2. Step 2

    Registration Deadline

  3. Step 3

    Conference Date

Download

Get the official templates and forms for ICIMRN 2027. Use the latest versions when preparing your submission.

Peer Review Process

Follow each step from abstract submission to awards and recognition.
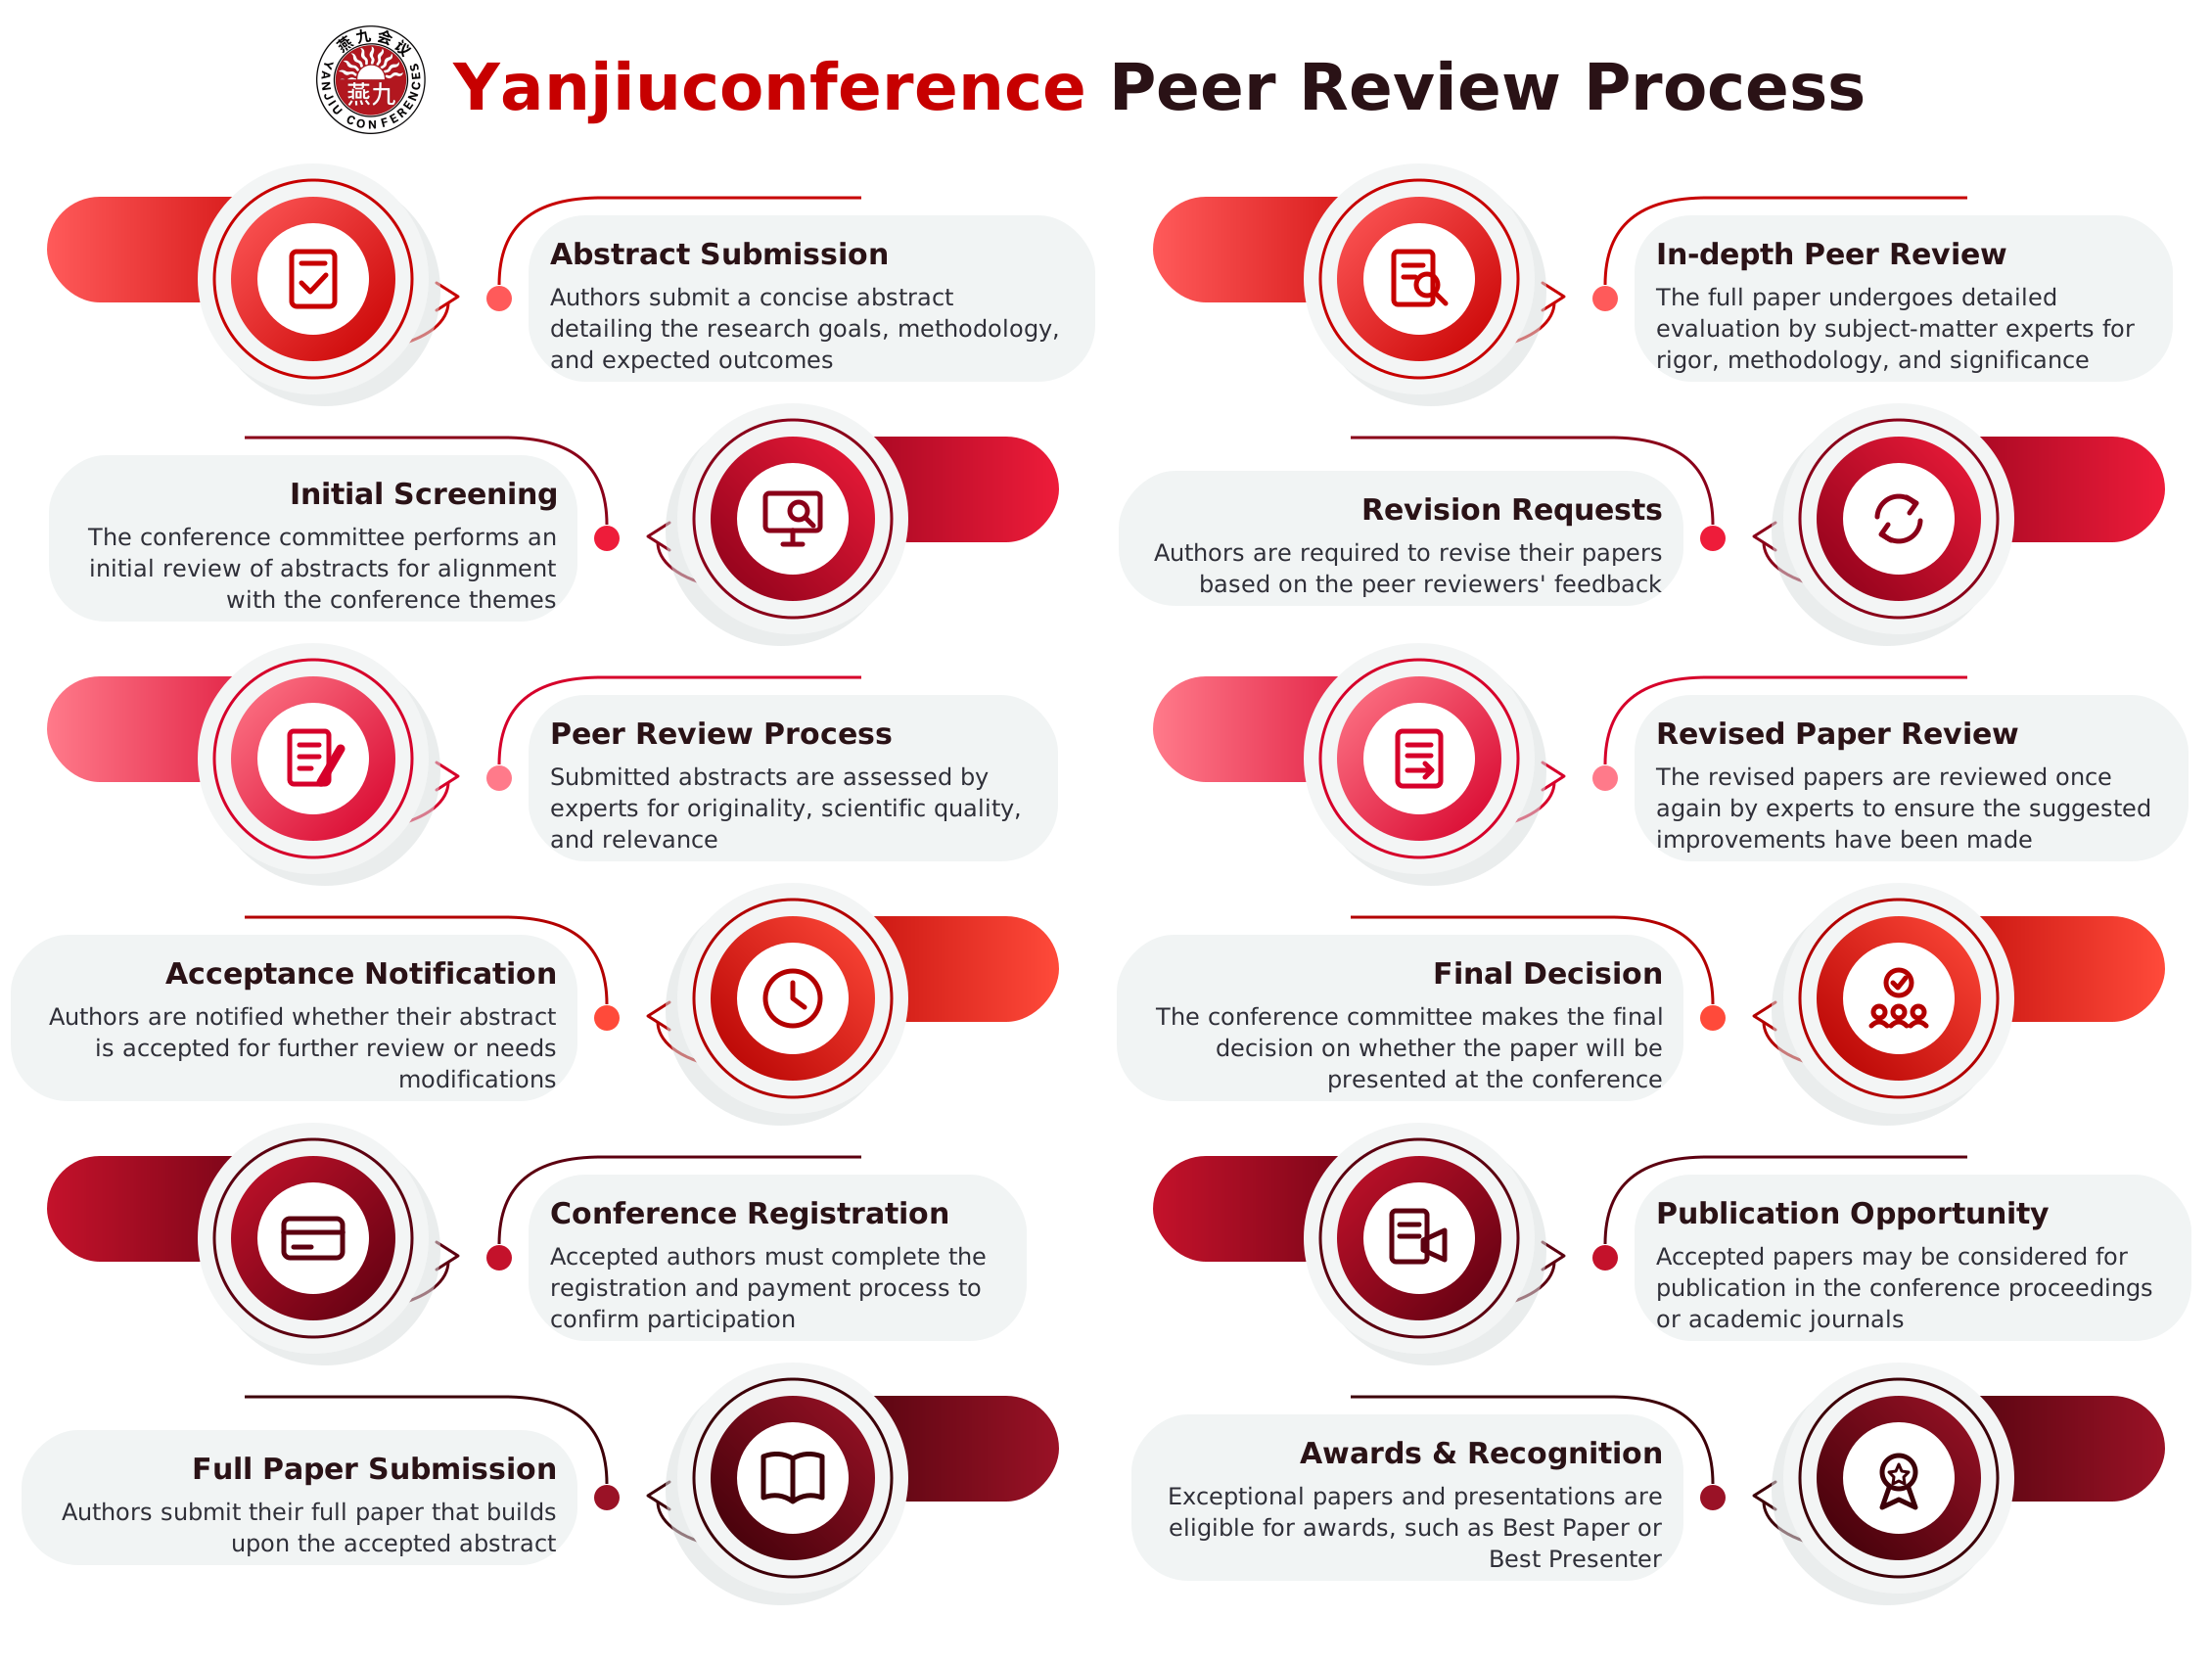
Yanjiuconference peer review process: 12 steps from abstract submission to awards and recognition

See You in Tagaytay This April

Present your research, meet peers from over 50 countries and help shape the future of Intelligent Mobile Robotics and Navigation.