Yanjiu Conference logo

Call for Papers – ICMRLC 2027, Pasig

International Conference on Multimodal Robotics and Language-Guided Control — ICMRLC 2027

Dates

2–3 February 2027

Venue

Pasig, Philippines

Field

Multimodal Robotics and Language-Guided Control

Topics of ICMRLC 2027

Original papers are invited in Multimodal Robotics and Language-Guided Control. Submit by 1 January 2027.

Submit Your Paper

Topics include, but are not limited to:

Language-Driven Interaction Models

  • Designing interactive models for human-robot dialogue
  • Developing natural language processing for commands
  • Evaluating effectiveness in diverse user scenarios
Multimodal Perception Systems

  • Integrating visual and auditory inputs in robots
  • Challenges in sensor fusion and interpretation
  • Applications in complex environments and tasks

Robotics in Assistance and Care

  • Exploring language-guided robotics in elder care
  • Addressing emotional and social interaction challenges
  • Case studies of assistive care technologies

Machine Learning Approaches

  • Utilizing reinforcement learning for language understanding
  • Developing algorithms for context-aware control
  • Challenges in training data diversity and quality

Evaluation Metrics for Multimodal Systems

  • Defining metrics for assessing multimodal effectiveness
  • Comparative studies of language versus gesture control
  • Longitudinal evaluation of user engagement

Important Dates

Conference opens in

00days
00hours
00min
00sec
  1. Step 1

    Submission Deadline

  2. Step 2

    Registration Deadline

  3. Step 3

    Conference Date

Download

Get the official templates and forms for ICMRLC 2027. Use the latest versions when preparing your submission.

Peer Review Process

Follow each step from abstract submission to awards and recognition.
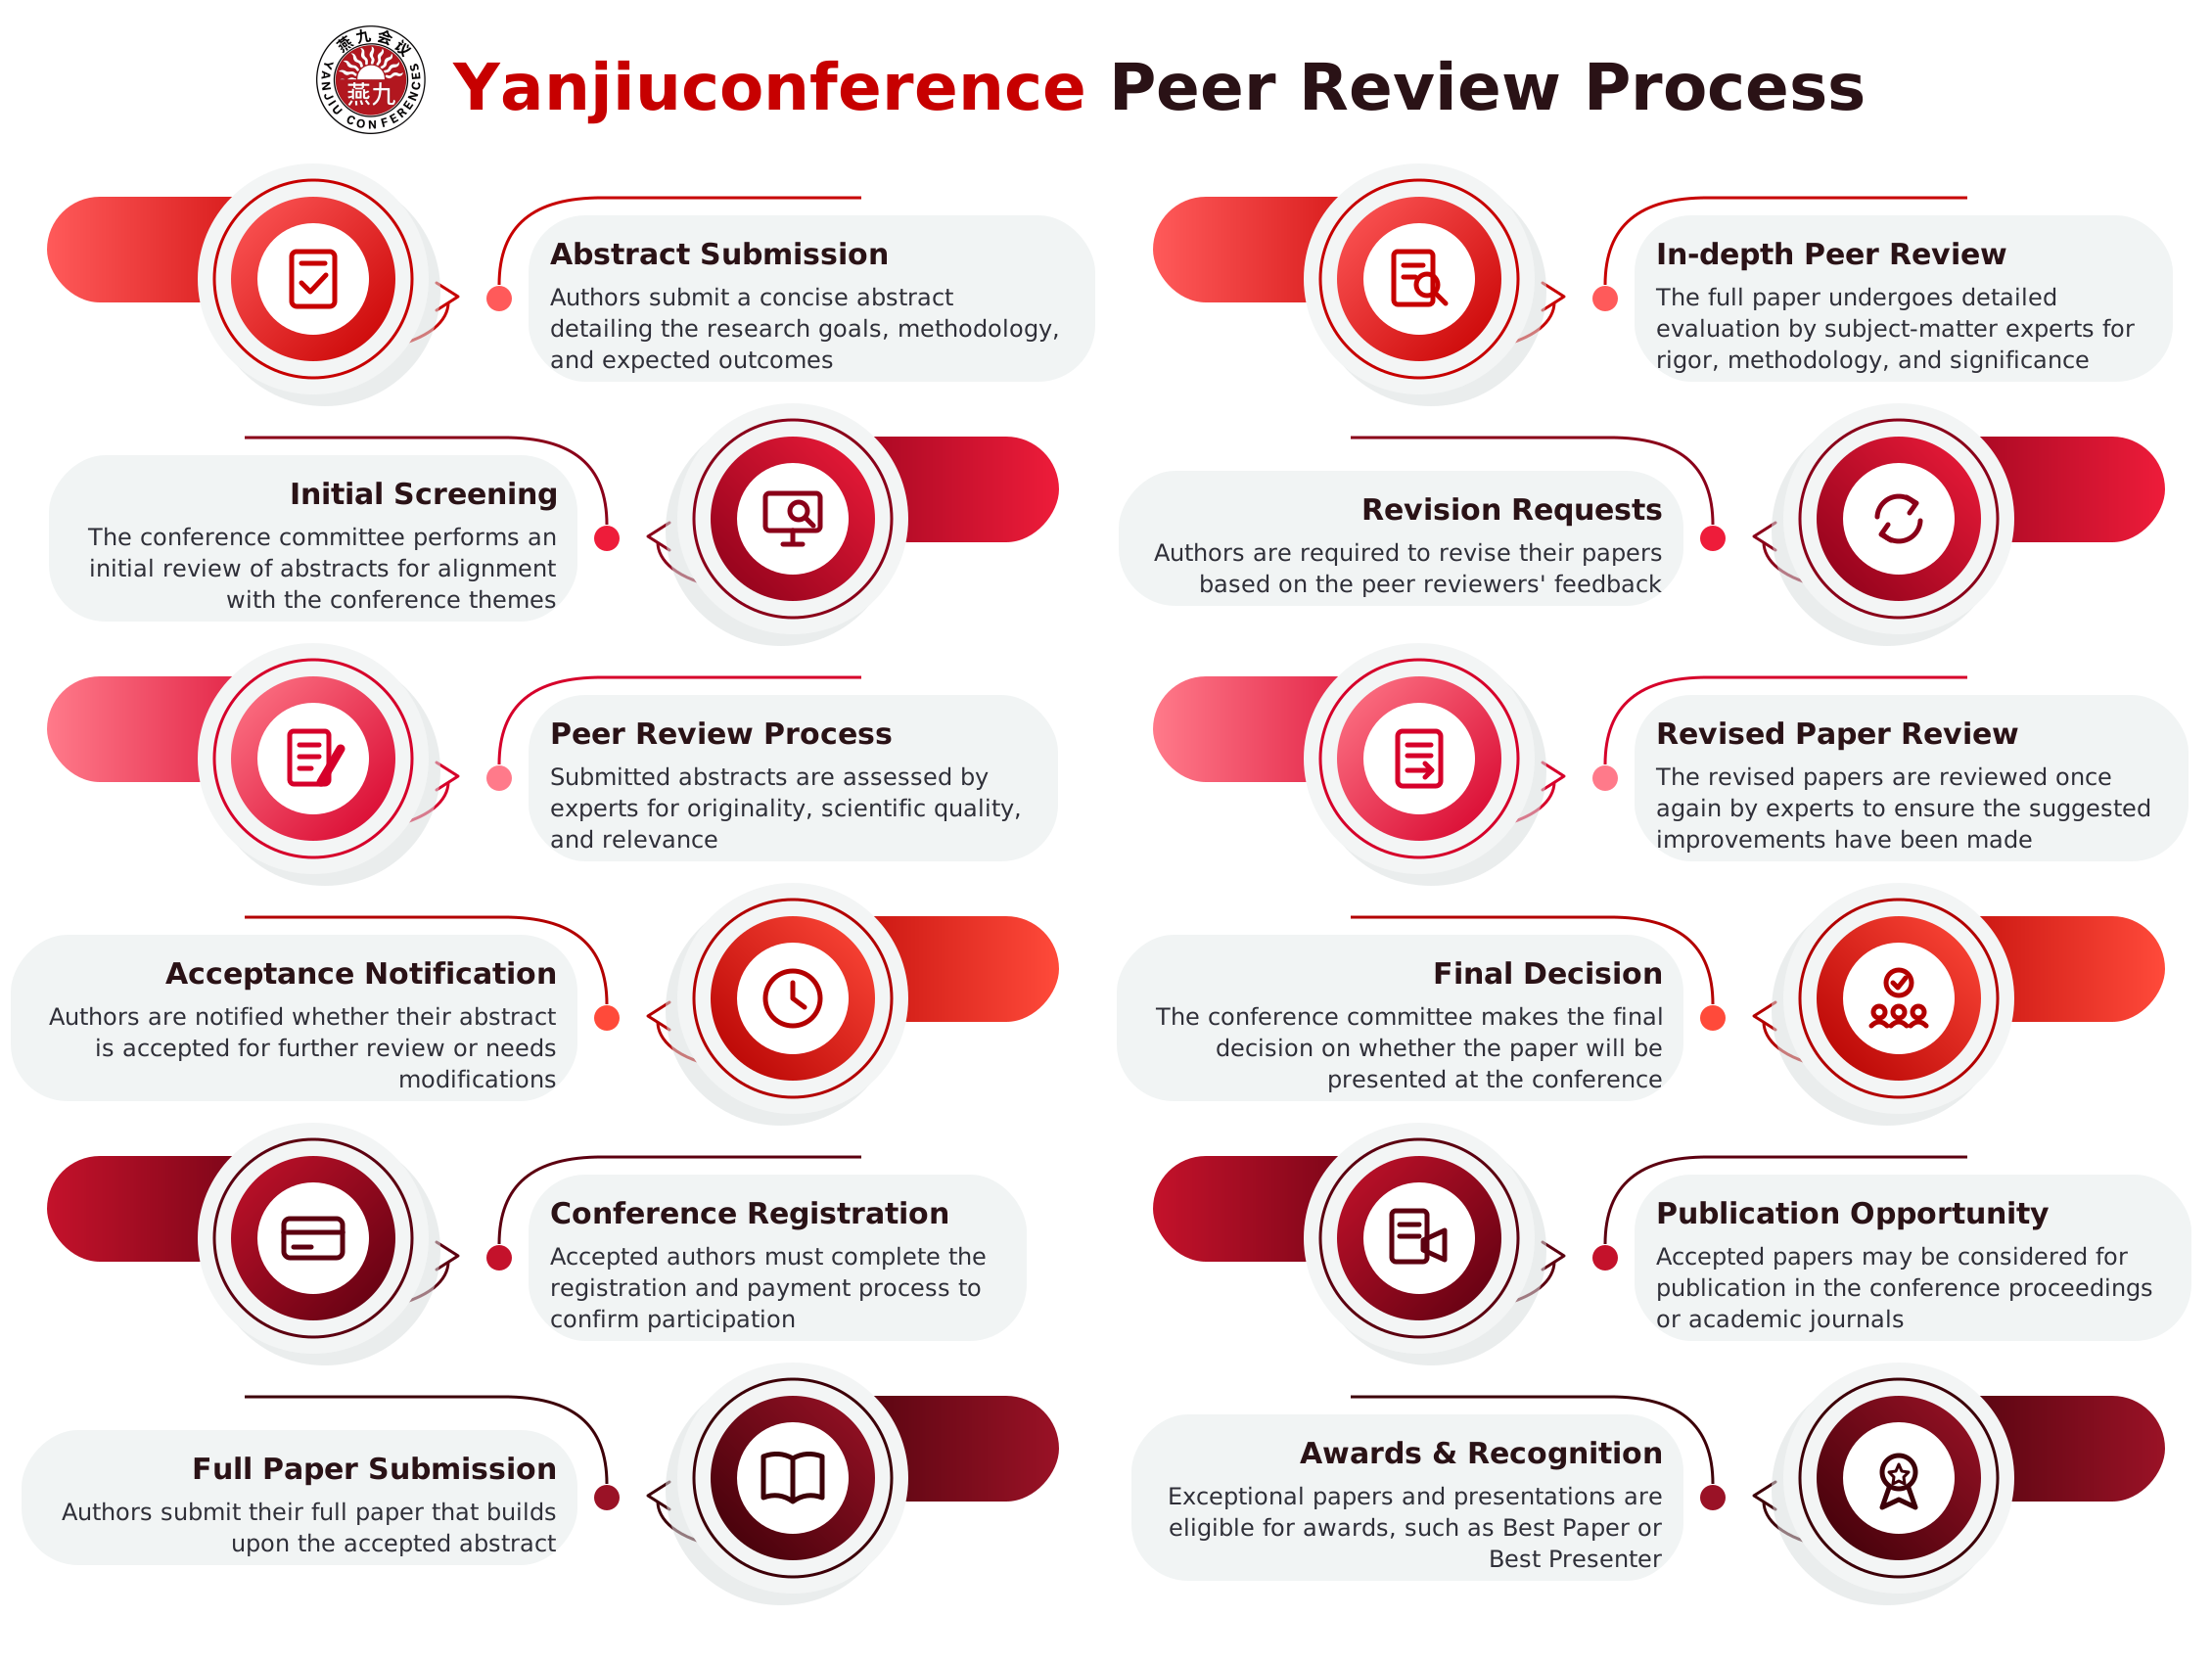
Yanjiuconference peer review process: 12 steps from abstract submission to awards and recognition

See You in Pasig This February

Present your research, meet peers from over 50 countries and help shape the future of Multimodal Robotics and Language-Guided Control.