Principles of Learning from Demonstration
- Theoretical frameworks for robot learning
- Data efficiency in learning systems
- User-guided learning mechanisms
International Conference on Robot Learning from Demonstration and Interaction — ICRLDI 2027
Dates
25–26 January 2027
Venue
Hong Kong, Hong Kong
Field
Robot Learning from Demonstration and Interaction
Original papers are invited in Robot Learning from Demonstration and Interaction. Submit by 24 December 2026.
Topics include, but are not limited to:
Conference opens in
Step 1
Step 2
Step 3
Get the official templates and forms for ICRLDI 2027. Use the latest versions when preparing your submission.
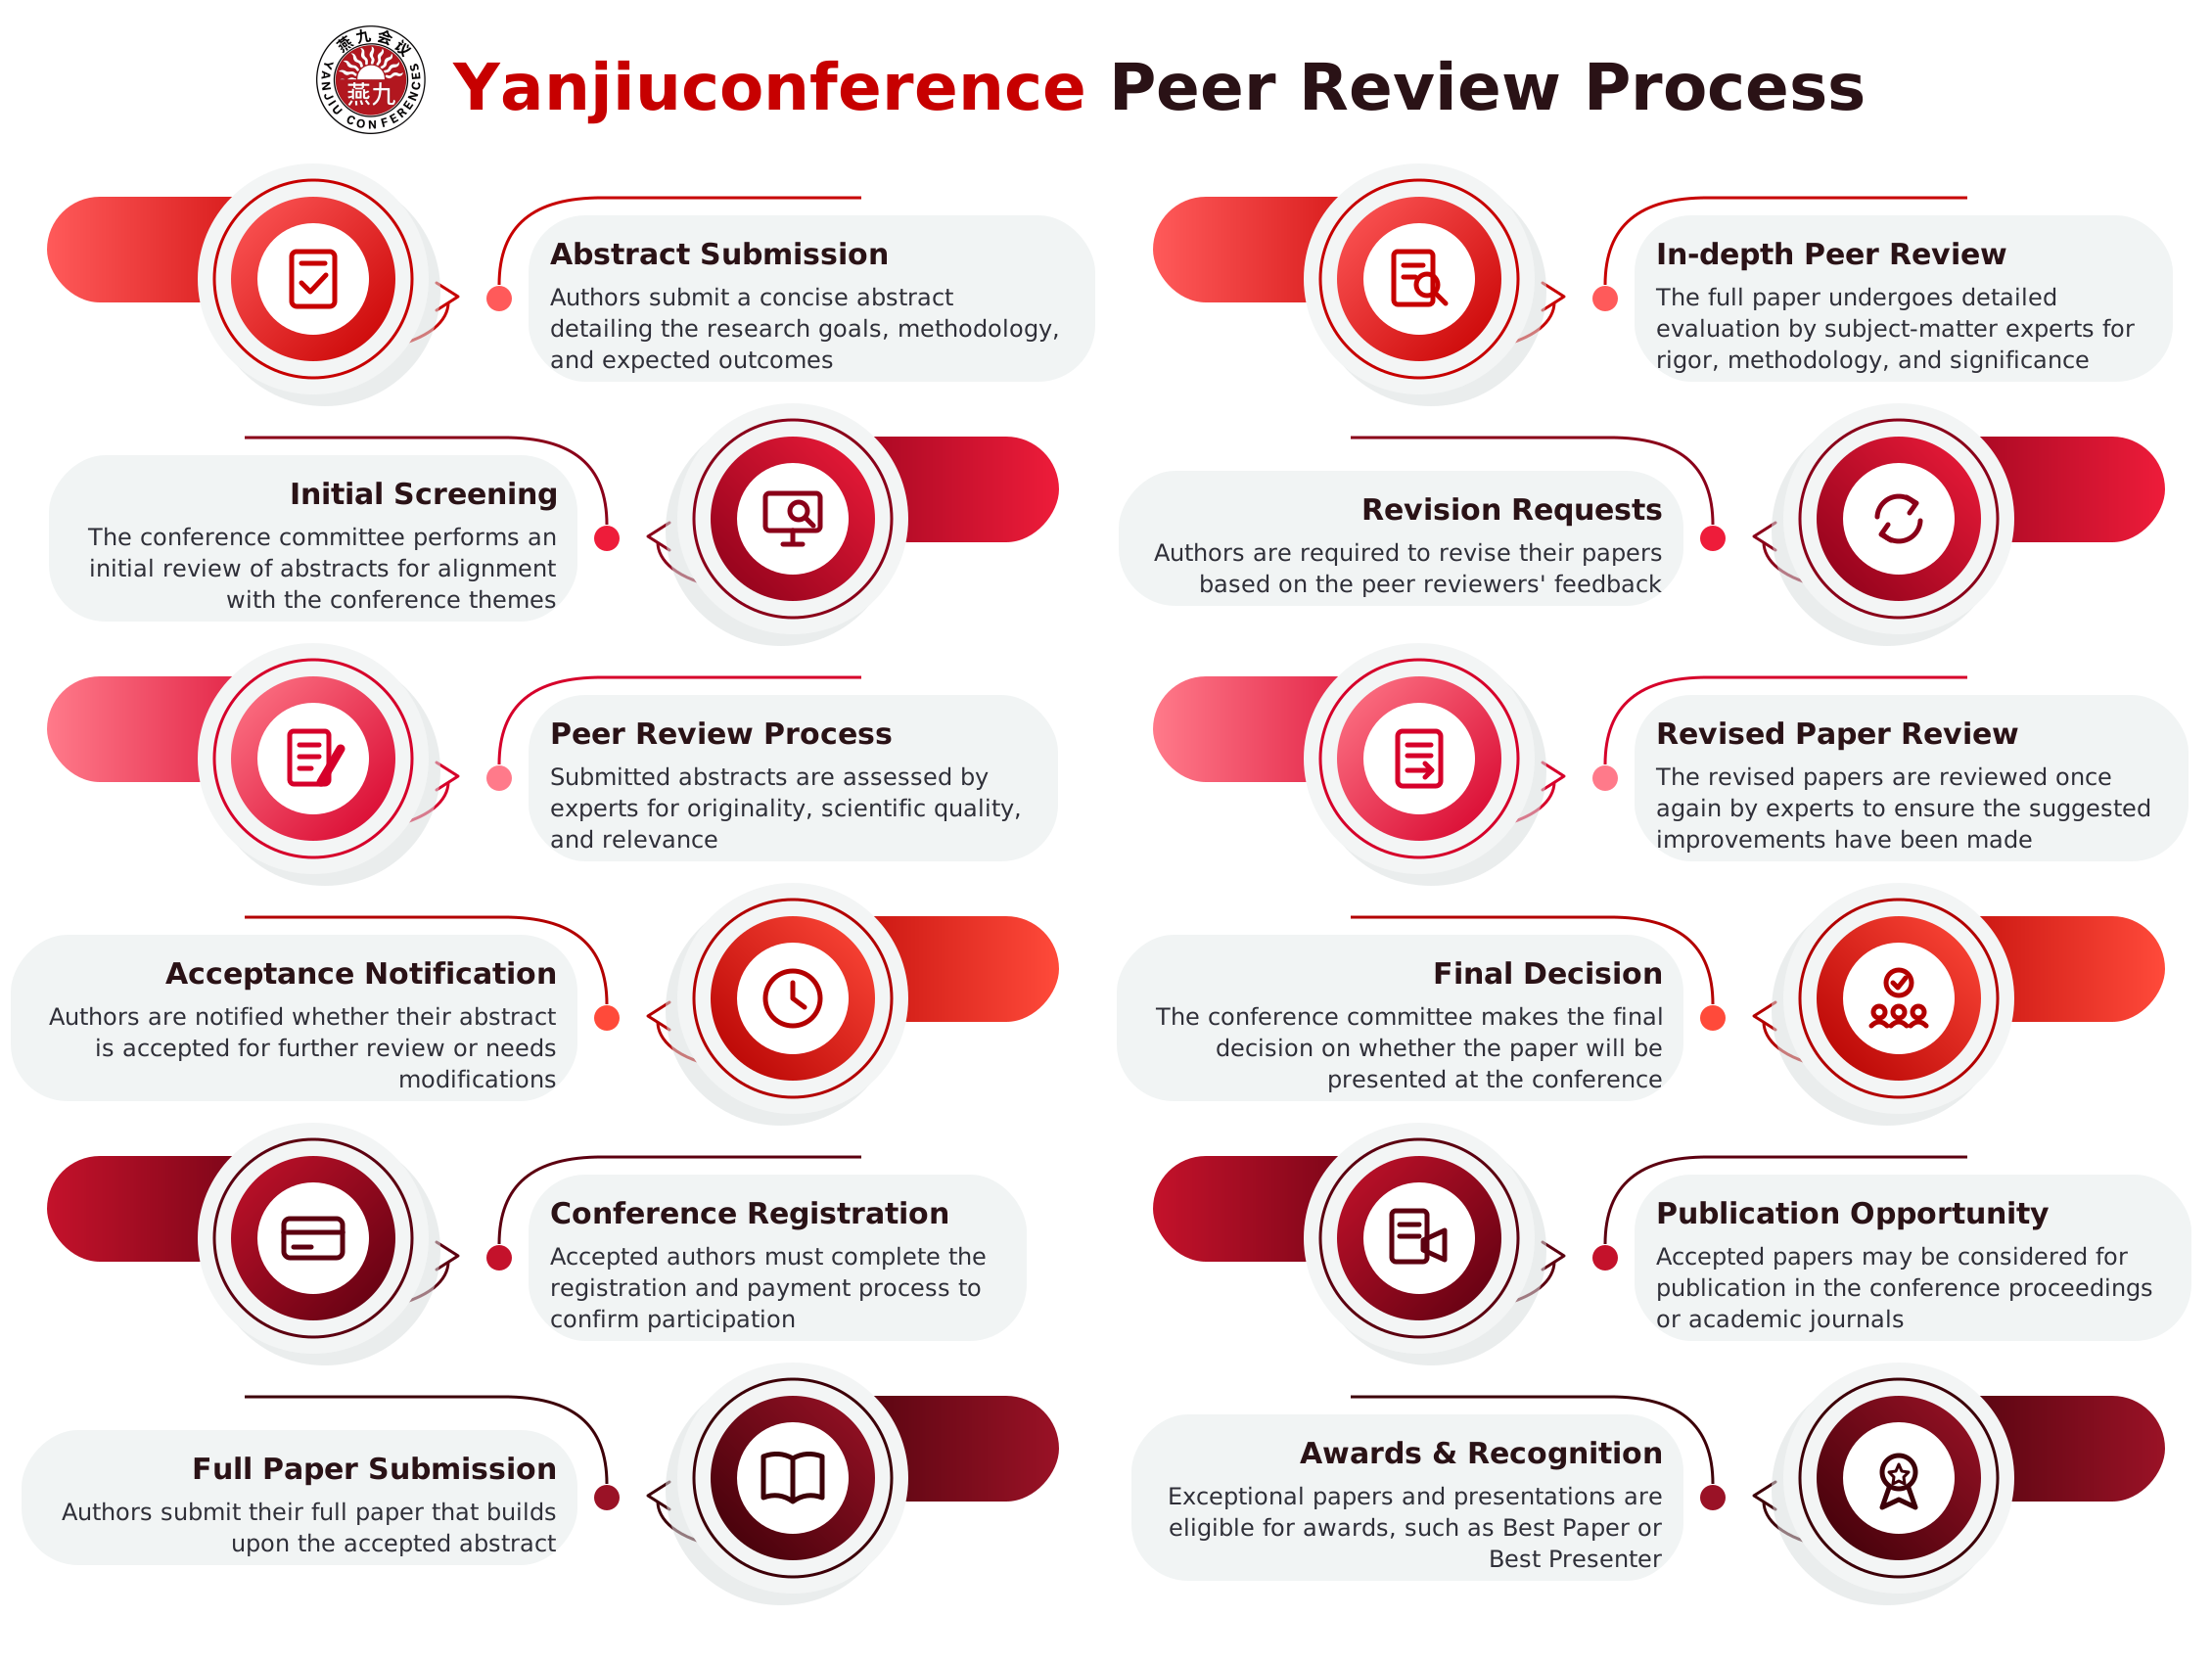
Follow each step from abstract submission to awards and recognition.
Present your research, meet peers from over 50 countries and help shape the future of Robot Learning from Demonstration and Interaction.