Yanjiu Conference logo

Call for Papers – ICSRCN 2027, Hong Kong

International Conference on Swarm Robotics and Cooperative Navigation — ICSRCN 2027

Dates

25–26 January 2027

Venue

Hong Kong, Hong Kong

Field

Swarm Robotics and Cooperative Navigation

Topics of ICSRCN 2027

Original papers are invited in Swarm Robotics and Cooperative Navigation. Submit by 24 December 2026.

Submit Your Paper

Topics include, but are not limited to:

Swarm Intelligence Algorithms

  • Development of bio-inspired optimization strategies
  • Analysis of emergent behaviors in robotic swarms
  • Comparison of swarm algorithms in dynamic environments
Cooperative Navigation Techniques

  • Methods for real-time path planning among multiple agents
  • Integration of GPS and local sensing systems
  • Challenges in large-scale coordinated movements

Interdisciplinary Applications of Swarm Robotics

  • Use cases in environmental monitoring and disaster response
  • Innovations in agriculture through swarm technology
  • Collaborative robotics in industrial automation

Communication Protocols in Swarm Systems

  • Design of robust communication frameworks for coordination
  • Impact of communication delays on swarm performance
  • Assessment of decentralized vs centralized communication models

Performance Metrics and Evaluation

  • Establishing benchmarks for swarm effectiveness
  • Quantitative measures for cooperative behavior
  • Simulation vs real-world performance assessments

Important Dates

Conference opens in

00days
00hours
00min
00sec
  1. Step 1

    Submission Deadline

  2. Step 2

    Registration Deadline

  3. Step 3

    Conference Date

Download

Get the official templates and forms for ICSRCN 2027. Use the latest versions when preparing your submission.

Peer Review Process

Follow each step from abstract submission to awards and recognition.
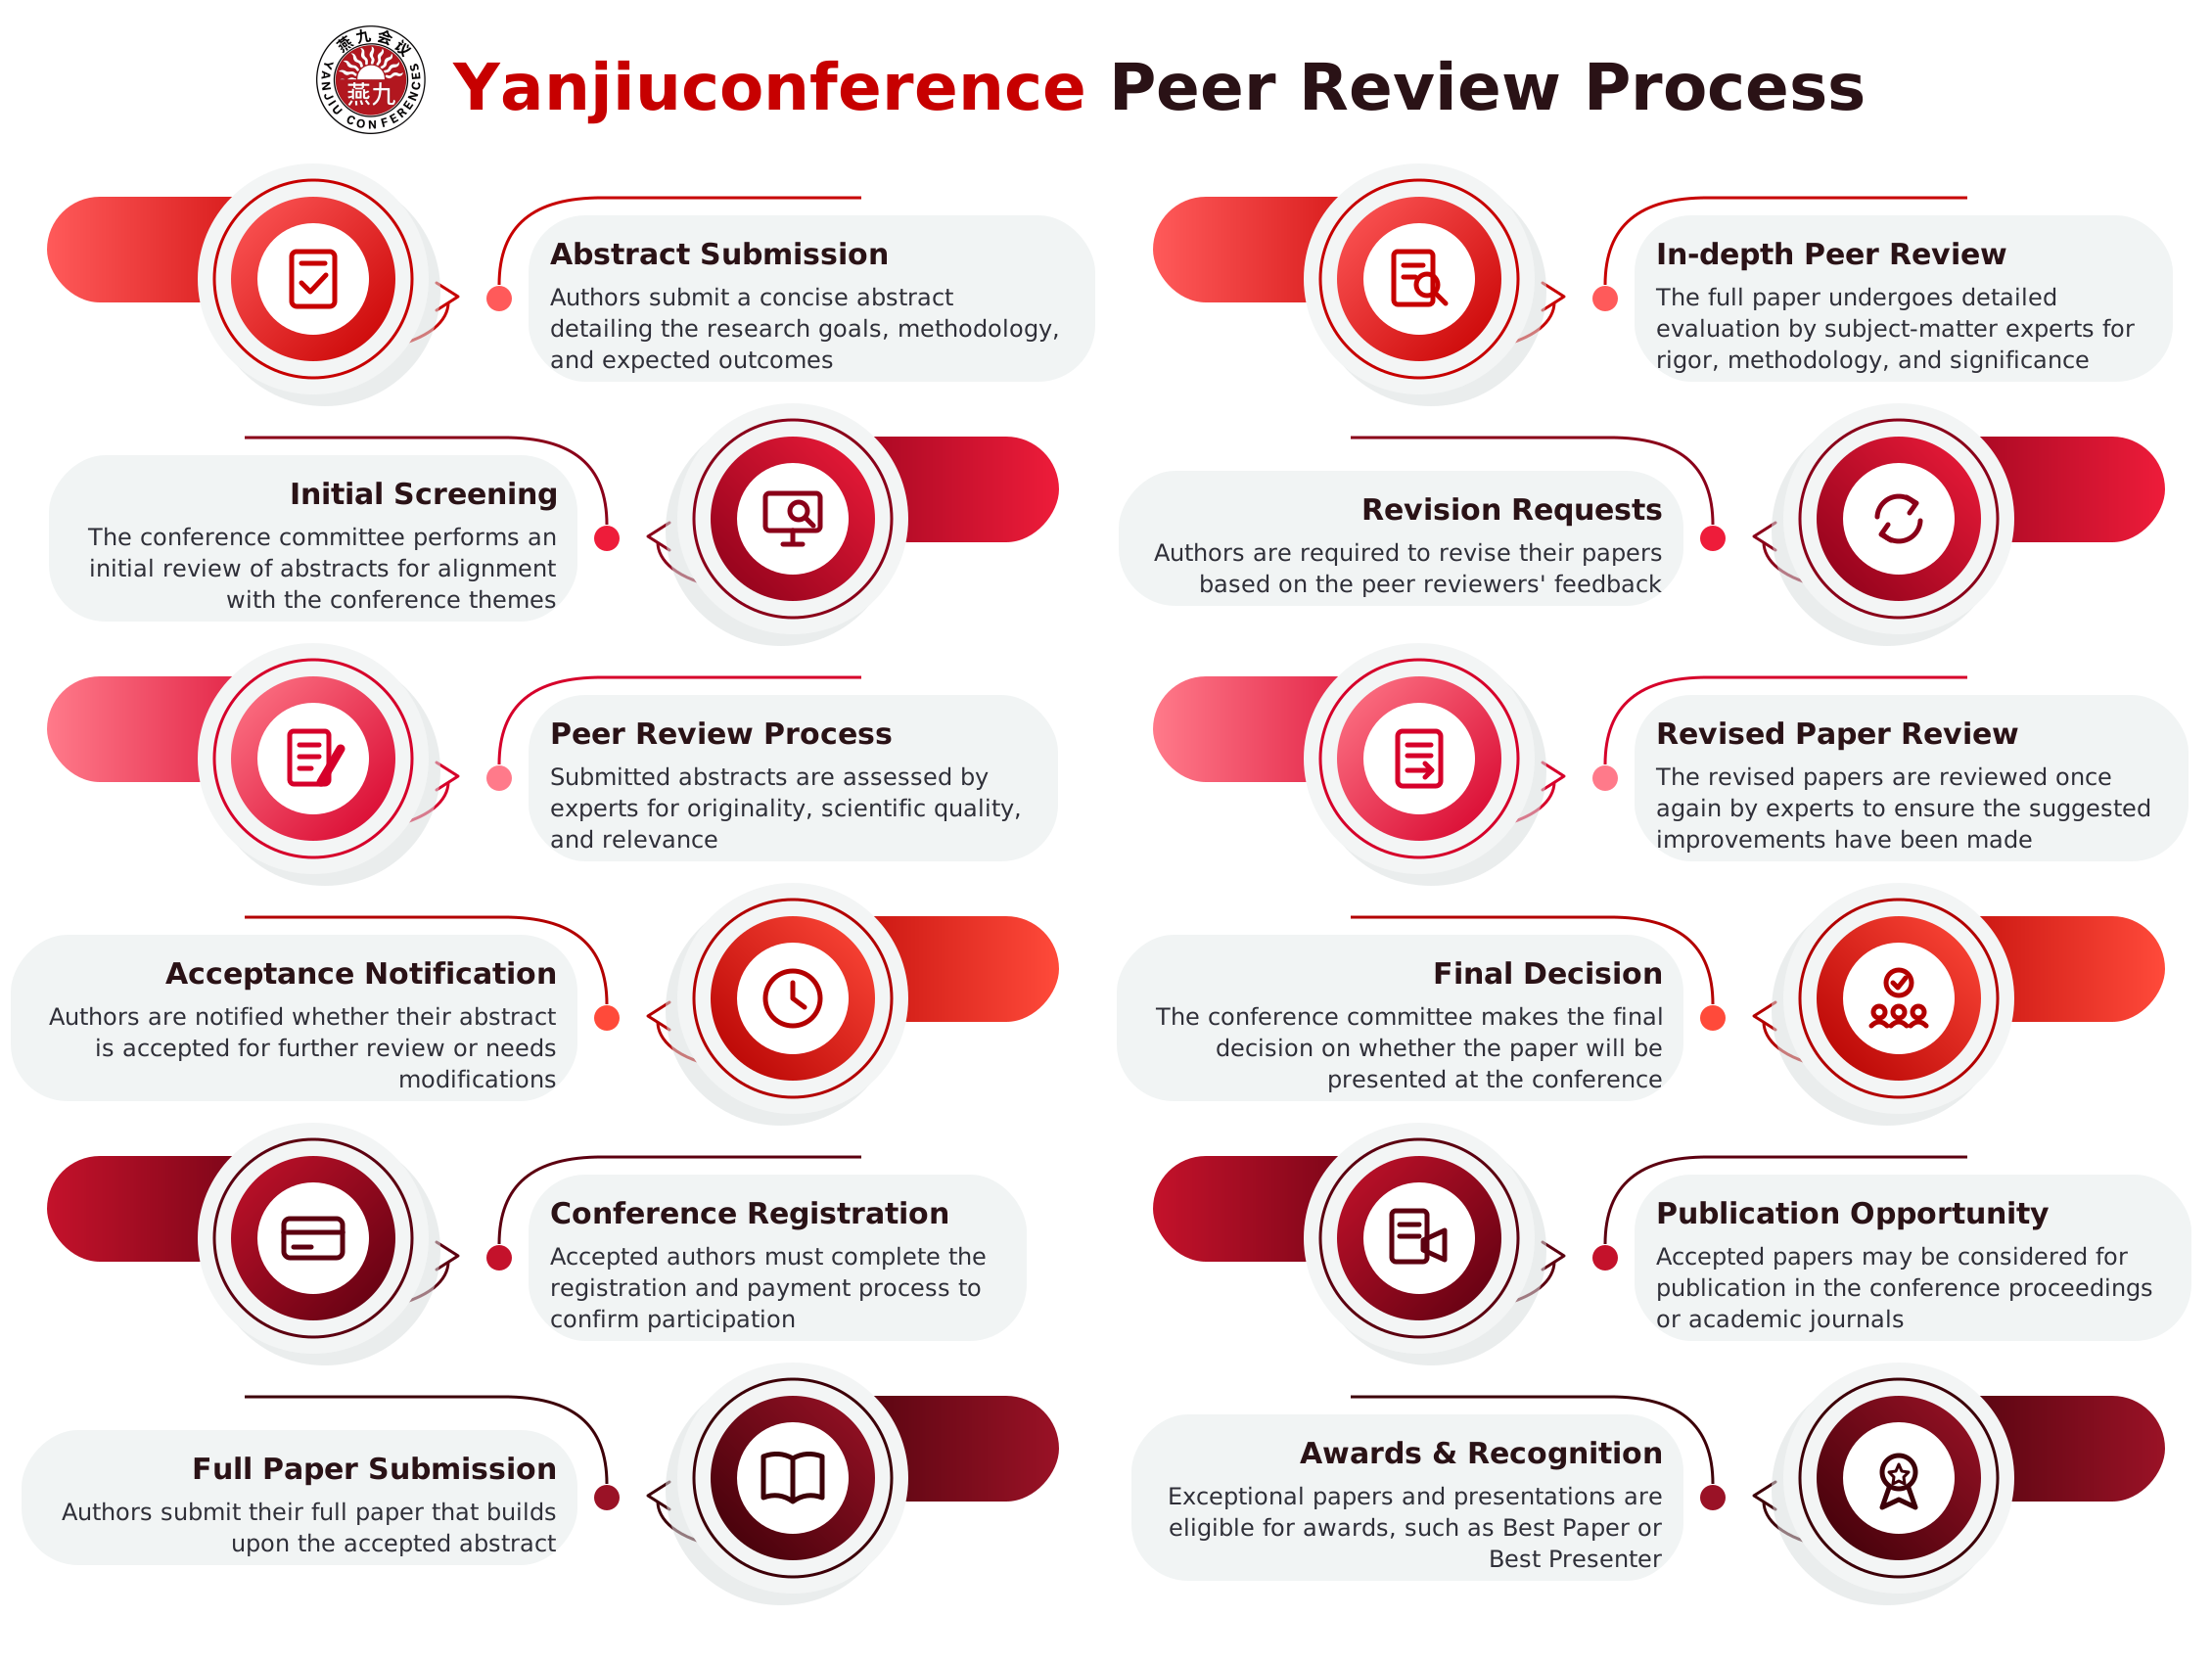
Yanjiuconference peer review process: 12 steps from abstract submission to awards and recognition

See You in Hong Kong This January

Present your research, meet peers from over 50 countries and help shape the future of Swarm Robotics and Cooperative Navigation.